Professional designer and manufacture of CCD machines for ONE STOP SOLUTION.
Language
Professional designer and manufacture of CCD machines for ONE STOP SOLUTION.
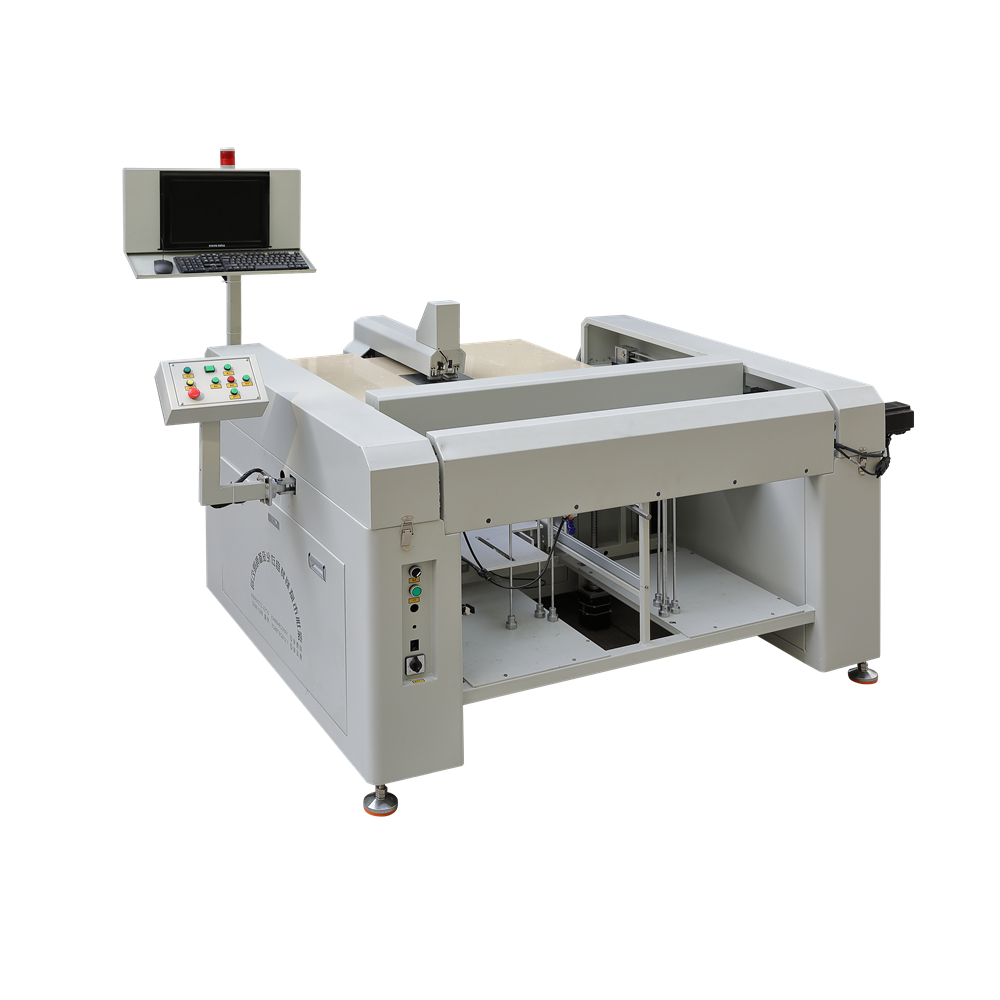
Product Model: VTS15-02
Maximum Feeding Size: 400×400mm (Can be customized)
The Working Process: Automatic feeding, automatic punching, automatic collecting
Positioning Way: Infrared sensor collet positioning, CCD camera scanning accurate positioning
Material Fixation Mode: Pneumatic chuck automatic clamping and fixing
Send Material Accuracy: ≦ + / - 0.1 mm
Repeat Position Accuracy: ≦ + / - 0.1 mm
Shenzhen VILITY Automatic Machinery Co.,Ltd established in 2010 year, located in Shenzhen city, China. Our company’s development approach is : People-oriented, Technological innovation , service-oriented. VILITY is a combine-word, comes from Victory& Ability and Victory &Quality which means we always pursue high quality and good service to meet customers requirements and high competitive market. We believe: Service first, customers supreme. VILITY is a Professional manufacturer, providing ONE-STOP SOLUTION for intelligent printing industry. Recent years, We have pay most of the techniques and technologies to implement Industry 4.0 Robotic. VILITY has been successfully Provide unmanned production lines for many customers. Therefore, it is honored to get a high degree of social affirmation. Our main products are CCD automation alignment machines which included in: CCD guide hole punching machine, CCD screen printing machine, CCD die cutting machine, CCD Fitting machine, Automation CCD testing machine for screen printing, Hardware, plastics and other industries. Those machines suit for both flat material and roll to roll material. With substantial ongoing investment in research and development, VILITY is ideally positioned to continue doing high precision CCD robotic machines for both the commercial and domestic markets. We are looking forward to establishing well long –term business relationship with you and your esteemed companies.
1. A stack of material, through the robot will be the most surface material through the suction cup to suck up the material into the area to be punched;.
2. The table top robot senses the material, aligns the material to be punched against the edge through the cylinder, and pushes it to the standby feeding robot chuck.
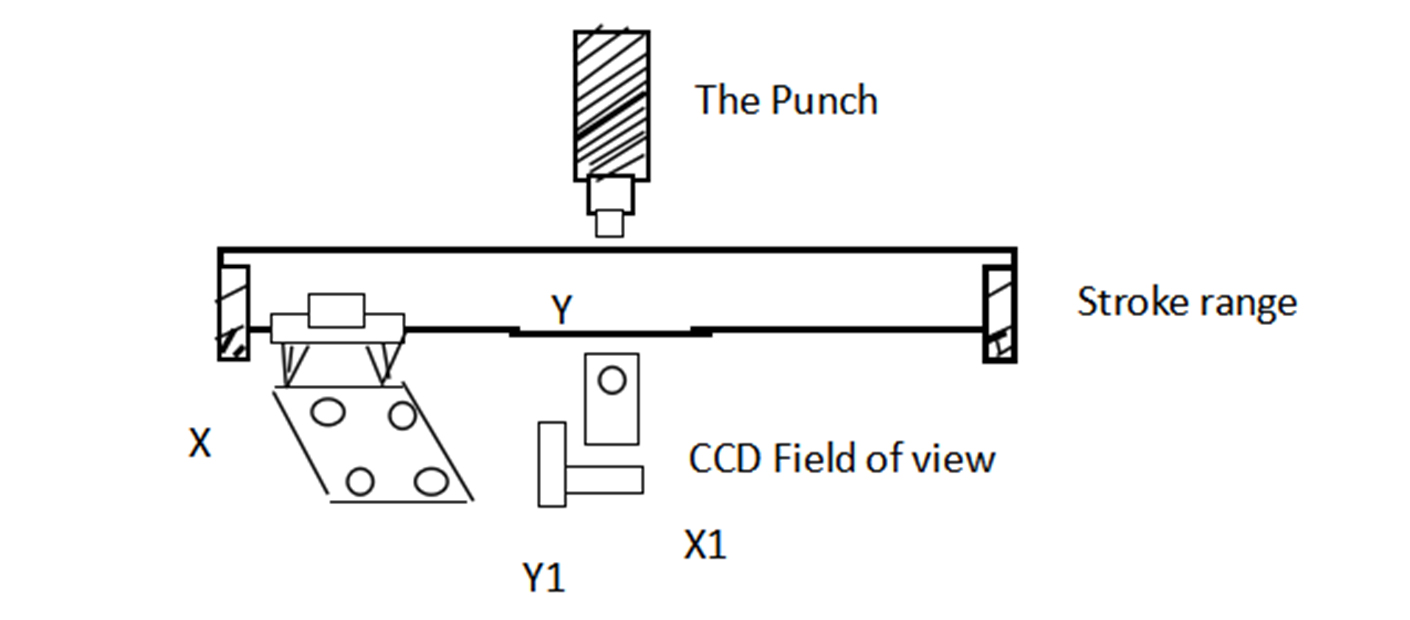
3. The manipulator sends each hole into the CCD scanning range by pre-inputting the alignment hole path and following the path.
4. In the CCD scanning capture range, CCD will adjust the error sent to the next workpiece set X1, Y1 move and implement positioning punching.
5. After the punching is completed, the perforated finished material will be sent to the area to be received, and the induction switch sensing the material will start the receiving robot to suck the finished material to the receiving frame.
6. The loading - clamping - up and down double stations work in parallel with punching - unloading to realize the continuous work of punching mechanism without stopping. The speed is only limited by the reaction time and movement time of the punching mechanism, and no human participation is needed in the working process, which completely realizes the fully automatic punching machine.
Product model | VTS15-02 |
Maximum feeding size | 400×400mm (Can be customized) |
The working process | Automatic feeding, automatic punching, automatic collecting |
Positioning way | Infrared sensor collet positioning, CCD camera scanning accurate positioning |
Material fixation mode | Pneumatic chuck automatic clamping and fixing |
Send material accuracy | ≦ + / - 0.1 mm |
Repeat position accuracy | ≦ + / - 0.1 mm |
Punching accuracy | ≦ + / - 0.02 mm |
Maximum feeding thickness | 2mm |
Maximum feeding width | 400×400mm (Can be customized) |
Theoretical feeding speed | 0.35 S/hole) |
Actual feeding speed | 0.6s/hole (depending on material size and material) |
Drive way | The driving part is driven by motor, and the clamping and punching are driven by cylinder |
Equipment weight | Net weight 390kg (punching station) +100Kg (feeding station) +10kg |
1. Fast punching speed and high production efficiency.
2. CCD in the visual range to find the map, image acquisition stable and efficient.
3. High degree of automation, the user only needs to put the workpiece into the corresponding station, fully automatic.
4. Using embedded system plus PC control, the controller adopts DSP chip, PC control punching software, software upgrade only need to upgrade the punching software to ensure high performance.
1. Image recognition
Image recognition is realized by means of CCD image sensor + DSP.
CCD image sensor is a photoelectric conversion image sensor, the use of photoelectric conversion principle to image information directly into electrical signals. It has the characteristics of self-scanning, fast working speed, high measurement accuracy and long life. DSP chip, that is, digital signal processor, is specially designed for the rapid implementation of various digital signal
algorithm and designed with a special structure of the microprocessor, its processing speed has been as high as 2000MIPS, than the fastest CPU is also 10-50 times faster.
The image recognition system uses CCD to convert the workpiece into electrical signal by A/D conversion and then sends it to DSP for processing. Using the feature that DSP can process digital signal at high speed, the workpiece is recognized and analyzed and the punching position is positioned in a very short time. Our company mainly adopts imported CCD camera from Japan WATEC for graphic identification.
2. Motion structure
Adopt a large range on the workpiece set to go according to the map. Input the positioning hole to be punched, (Figure 1) the sheet to be punched under the suction of the fixture moves up and down with the large workpiece X, Y axis back and forth, moving the sheet to the CCD range, the camera automatically captures the graphics. the DSP chip analyzes the graphics data and sends a signal to control the workpiece set X1, Y1 move to precisely locate. Motion structure our company in the screw, guide / slider mainly uses Taiwan on the silver H-class high-precision transmission components to ensure quality. 57 series stepper motor for CCD positioning to ensure fast speed, torque stability; driver using the highest end of the Raisai imitation servo drive no noise stability, small range of high precision. Wide range of travel motor drive using Japan's Sanyo, synchronization performance, good stability, low noise.
3. Pneumatic part
After the positioning capture is completed, under the control of DSP chip, the solenoid valve is started and the switch is opened to control the up and down movement of the cylinder to punch the hole. In the pneumatic part, the cylinder and solenoid valve adopt the brand of Japan's small gold ware, stable and durable.
CONSULT OUR CUSTOMERS FOR SURPRISE DISCOUNTS
Please provide us with the information below to complete your request. Just leave your email or phone number in the contact form so we can send you a free quote for our wide range of designs!

VILITY is a Professional manufacturer, providing ONE-STOP SOLUTION for intelligent printing industry.

